Compact Cycloidal Gearbox for Humanoid Hand Joint
Screen pinch torque, holding loads and package fit for finger, thumb and palm actuators. Export an engineering RFQ.
Hand joint sizing calculator
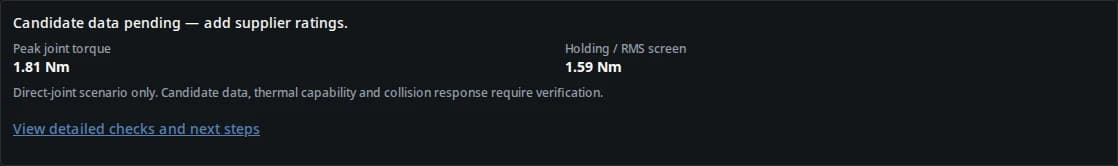
Direct-joint scenario only. Candidate data, thermal capability and collision response require verification.
View detailed checks and next stepsRequired · 0.01–0.5 kg. Combined mass of finger phalanges, linkages, fingertip elastomer pads and tactile sensors.
Required · 20–180 mm. Pivot-to-contact distance. This screen assumes contact force perpendicular to the lever and payload at the same radius; use a full Jacobian for other poses.
Required · 0–80 N. Normal contact force perpendicular to the lever. Do not enter whole-hand grip force or include payload gravity twice.
Required · 0–5 kg. Additional payload share at the fingertip, separate from the entered normal force. Set to zero if contact forces already account for payload loading.
Kinematics, dynamics and envelope assumptions (editable)
Candidate reducer datasheet verification (optional)
Leave blank if unknown. Defaults and presets supply no product data. Enter verified limits for the same speed, duty and temperature. Numeric matches are preliminary; thermal and physical qualification remain necessary.
Load 3 illustrative hand joint scenarios
T_static = F_grasp·L_lever + (m_finger·L_com + m_payload·L_payload)·g·sin(θ). Center inertia sum (0.00015 kg·m²) is an assumption; zero is a point-mass lower bound. RMS is an assumed cycle value; sustained grasp holding requires continuous capacity for static torque. The screen uses max(static hold, assumed RMS); it is not a gear-life or thermal approval. Impact demand is an exploratory multiplier, not a dynamic crash simulation. Motor torque excludes motor rotor inertia and bearing friction. Remote tendons and multi-contact grasp equilibrium need a separate model.
Motor speed: required 1740 rpm; available 12000 rpm; margin 10260 rpm. Speed alone does not verify motor torque or thermal capacity.
Next: obtain 8 missing candidate ratings, or send these demands for a manual feasibility review.
Compare all 8 candidate torque, speed and package checks
| Design Parameter | Required Demand | Candidate Provided | Status & Margin |
|---|---|---|---|
Continuous capacity (holding / assumed RMS) | 1.59 Nm | Not specified | Pending |
Repeatable Peak Torque | 1.81 Nm | Not specified | Pending |
Impact / Shock Capacity | 5.43 Nm | Not specified | Pending |
Maximum Input Speed | 1740.00 rpm | Not specified | Pending |
Axial Length Envelope | 22.00 mm | Not specified | Pending |
Outer Diameter Envelope | 28.00 mm | Not specified | Pending |
Central Hollow Bore Clearance | 4.00 mm | Not specified | Pending |
Overturning Moment Capacity | 1.80 Nm | Not specified | Pending |
Manual RFQ text / export preview
Published · Reviewed by RV Reducer. Source-checked preliminary screening methodology; candidate qualification requires supplier data and physical validation. Sources checked on the review date. Next methodology review: 12 May 2027, or earlier if cited standards or supplier rating methods change. No production hand model or stock availability is verified here.
Key Decisions Before Shortlisting a Hand Reducer
Use this page to reject incompatible concepts and prepare a supplier review. All example loads and dimensions are illustrative inputs. No miniature cycloidal stock model, price, service life or contact-safety performance is verified.
| Decision | Evidence or page calculation | Next action |
|---|---|---|
| Check holding separately | Default contact 1.275 Nm + gravity 0.318 Nm = 1.593 Nm static. Assumed RMS is only 0.815 Nm; a 1.2 Nm continuous candidate must be rejected for sustained holding. | Use the larger of static hold and assumed cycle RMS as a preliminary continuous screen; confirm thermal derating. |
| Use research at its tested scale | The cited C-QDD study reports a 10:1, 1.40 kg legged-robot prototype, not a miniature hand reducer [cqdd-hand]. | Request measurements for the exact candidate; do not transfer prototype performance to a finger joint. |
| Separate inertia from backdrive | For one unchanged motor, 29² / 100² = 0.0841; only the rotor inertia contribution falls by 91.59% (page derivation). | Measure breakaway torque and control response. No safety conclusion follows from ratio alone [iso-robot-safety]. |
| Check structure and routing | Cross-roller rings can carry radial, axial and moment loads [cross-roller-bearing]. Integration and hollow-bore dimensions are candidate-specific. | Obtain a section drawing and bearing load/deflection limits for your pose and wiring. |
| Budget for qualification | Torque ratings distinguish continuous, repeated peak and emergency events [harmonic-ratings]. Production availability and cost are unknown. | Agree duty, shock pulse spectrum, acceptance tests, NRE and delivery before ordering. |
Calculation Method and Applicability
This is a conservative, direct-joint rigid-body screen. Contact, gravity and acceleration torque magnitudes are added as if simultaneous and opposing the actuator. The model does not solve multi-contact equilibrium. Do not count payload weight twice; use zero additional payload when contact forces already include it. Input ranges are tool limits, not product specifications.
Equivalent direct-joint model, not anatomical CAD. CoM is fixed at L/2; additional payload is at L. The illustrated pose has θ = 90°.
Enter perpendicular contact force and an independent additional payload. The calculation adds torque magnitudes conservatively; it does not solve multi-contact equilibrium or a tendon transmission.
| Output | Page equation (SI units) | Assumption or exclusion |
|---|---|---|
| Contact torque (Nm) | T_contact = F_normal × L | Force is perpendicular to the pivot-to-tip lever; other force directions require vector moments. |
| Gravity torque (Nm) | T_gravity = (m_f × 0.5L + m_p × L) × 9.80665 × sin(θ) | Angle from downward vertical; finger CoM at half length and additional payload at tip. |
| Acceleration torque (Nm) | J_load = J_central + m_f(0.5L)² + m_pL²; T_acc = J_load × α | CAD central inertias parallel to joint axis; α in rad/s². Excludes rotor, gear and tendon dynamics. |
| Peak / continuous screen (Nm) | T_peak = T_contact + T_gravity + T_acc; T_cont_screen = max(T_static, k_RMS × T_peak) | Assumed RMS is illustrative. Supplier gear average-load/life methods and actual thermal cycles are separate. |
| Shock sensitivity (Nm) | T_shock = k_shock × T_peak | No contact-stress, impact-energy or collision-safety calculation. Obtain approved pulse duration and cycle count. |
| Speed and motor load | n_out = ω_deg/s / 6; n_in = N × n_out; T_motor_load = T_peak / (N × η) | Compare required speed to available loaded motor speed and reducer speed rating. Motor current, rotor acceleration and friction are excluded. |
| Power and rotor multiplier | P_envelope = T_peak × ω_rad/s; multiplier = N² | Simultaneous power envelope, not average electrical power. N² is not actual reflected inertia or a backdrive prediction. |
Three Reproducible Direct-Joint Examples
These are the three calculator presets, not measured commercial hand benchmarks. Each assumes perpendicular contact, a finger CoM at half the lever and an additional tip payload. Load a preset to inspect every input; candidate fields remain blank.
All inputs for the captured default run
Finger and phalanx link mass: 0.08 kg Effective finger lever arm to fingertip: 85 mm Target fingertip normal pinch/grasp force: 15.0 N Additional cantilevered payload per finger: 0.5 kg Combined finger and payload CAD central inertia: 0.00015 kg·m² Load lever angle from downward vertical: 45 deg Peak joint angular velocity: 360 deg/s Peak joint angular acceleration: 3200 deg/s² Proposed reduction ratio: 29 :1 Available motor loaded speed: 12000 rpm Assumed forward efficiency: 85 % Assumed RMS / peak torque ratio: 0.45 × Assumed impact torque multiplier: 3.0 × peak Lateral / twisting moment load: 1.8 Nm Gearbox axial length budget: 22 mm Outer diameter budget: 28 mm Minimum hollow bore diameter: 4 mm
| Illustrative preset | Key inputs | Calculated outputs | Decision |
|---|---|---|---|
| Precision fingertip pinch | 12 N; L 75 mm; payload 0.3 kg; θ 45°; J_central 0.00010 kg·m²; α 3600 deg/s²; N 25; speed 360 deg/s | Static 1.072 Nm; peak 1.189 Nm; required input 1500 rpm. | Continuous candidate must cover at least 1.072 Nm before derating; verify the force/payload load split. |
| Power grasp / thumb base | 28 N; L 95 mm; payload 1 kg; θ 60°; J_central 0.00030 kg·m²; α 2400 deg/s²; N 35; speed 240 deg/s | Static 3.515 Nm; peak 3.917 Nm; required input 1400 rpm. Larger payload and lever increase demand. | Compare holding and shock demands, then verify the 32 mm OD / 25 mm axial design budget with a supplier. |
| High-speed tactile probing | 6 N; L 70 mm; payload 0.1 kg; θ 30°; J_central 0.00008 kg·m²; α 6000 deg/s²; N 19; speed 600 deg/s | Static 0.463 Nm; peak 0.529 Nm; required input 1900 rpm. | Low modeled torque does not validate tapping safety; test contact dynamics and rotor inertia. |
Transmission Alternatives and Trade-offs
Compare actual candidates at the same load, size, duty and test conditions. The schematic shows one possible arrangement; no architecture is assigned a universal shock or backdrive rating.
Concept schematic only, not a verified product drawing; not to scale. 1: eccentric input. 2: phased discs and stationary ring. 3: output carrier. 4: possible output bearing.
Supplier verification is required for bore routing, bearing integration, torque, deflection and assembly clearances. No stock size or impact performance is implied.
| Architecture | Potential fit | Trade-off / unknown | Evidence needed |
|---|---|---|---|
| Compact cycloidal | A multi-contact reduction concept worth exploring when torque and package can be demonstrated. | Miniaturization, eccentric dynamics, preload and manufacturing tolerances affect friction, ripple and cost. | Exact envelope drawing; measured efficiency, backlash, backdrive and repeated-pulse endurance [cqdd-hand]. |
| Strain-wave | Coaxial high reduction may suit a low-speed positioning joint. | Repeated peak and emergency ratings differ; actual ratio and motor inertia determine reflected contribution. | Application-specific torque, life and speed selection; housed-unit bearing and bore details [harmonic-ratings]. |
| Micro planetary | Modular motor/gearhead sourcing may simplify a palm package. | Stage count, backlash, hollow-shaft options and external support vary by product. | Supplier drawings and measured backlash, bearing loads and shock limits; no generic tooth-failure ranking asserted. |
| Direct drive / remote tendon | Direct drive removes gear reduction; a remote tendon can move motor mass away from fingers. | Motor torque density or routing friction, stretch, preload and calibration may dominate. A direct motor still has rotor inertia. | Full-hand geometry and tendon/pulley Jacobian; use a separate system model rather than this direct-joint candidate check. |
Known Inputs and Unverified Properties
An entered-limit match means only that the supplied scalar values cover this model. Unknown data must stay pending. Report conclusions are limited to the cited source scope or explicitly identified page derivations.
| Property | Known here | Still required |
|---|---|---|
| Loads and geometry | Editable scenario and CAD central-inertia inputs; fixed CoM and force-direction assumptions. | Actual contact poses, mass centers, payload support fractions and trajectory. |
| Torque and thermal capability | Conservative holding / assumed-RMS scalar screen. | Motor and reducer ratings at actual speed, temperature, lubrication and duty; no winding temperature predicted. |
| Impact and safety | A selectable impact multiplier only. | Approved repeated-pulse data, contact compliance and application risk assessment [iso-robot-safety]. |
| Backlash and backdrive | Not calculated. The legged-robot research measurements are not hand specifications [cqdd-hand]. | Candidate hysteresis, breakaway torque and control tests at several poses and temperatures. |
| Bearing life | A supplied moment capacity can be compared to entered lateral moment. | Radial/axial loads, combined-load life and oscillation review; ISO 281 excludes wear [iso-bearing]. |
| Supply and economics | No stock, price, lead time or production hand integration is verified. | Written supplier quote, NRE/MOQ, test costs, spare parts and delivery commitment. |
Risks with Concrete Mitigations
Prioritize conditions that could invalidate a promising scalar match before committing to a prototype or custom tooling.
| Risk | Trigger / consequence | Mitigation or alternative |
|---|---|---|
| Holding overheats the actuator | Low assumed RMS masks long static holds inside an enclosed palm. | Screen full hold torque, then run thermal soak in the final casing; consider lower force, shorter hold, passive holding or a larger palm actuator. |
| Routine impacts exceed approval | An emergency torque value is reused for repeated tapping. | Obtain an approved pulse spectrum and cycle count; add compliance or limit speed and acceleration. Leave shock data blank until approved [harmonic-ratings]. |
| Lateral loading binds the joint | The bearing/housing deflects under combined fingertip loads. | Check radial, axial and moment capacity together with stiffness; use external support if integration cannot be verified [cross-roller-bearing]. |
| Wiring fails in the bore | Cyclic twist, tight bends or connector interference. | Use cable-maker bend/twist limits, routing drawings and flex-cycle tests; compare external protected routing. |
| Model does not fit the mechanism | Coupled joints, remote tendons or non-perpendicular contact forces. | Use multibody statics/dynamics and the transmission Jacobian; request manual sizing with drawings. |
| Custom sourcing overruns budget | No proven sub-30 mm unit or new tooling / qualification needed. | Request NRE, MOQ, yield and test costs; compare a larger palm-mounted package or another transmission before tooling. |
Agree Tests Before Ordering
This is a buyer test-planning checklist, not a prescribed standard or certified pass specification. Agree measurable application limits with the supplier; the cited public scopes do not supply universal hand-joint acceptance numbers.
| Test | Method to agree | Acceptance basis |
|---|---|---|
| Holding and dynamic duty | Measure torque/speed and temperature through representative cycles and longest hold in the final enclosure. | Supplier motor, gearbox, lubricant, sensor and touch-surface limits at worst ambient; document derating. |
| Hysteresis and fingertip error | Specify bidirectional torque sweep, preload, load level, temperature and encoder resolution. | Derive allowed angular error from fingertip positional tolerance. ISO 9283 is robot-level context, not a component hysteresis threshold [iso-hysteresis]. |
| Backdrive and control response | Measure breakaway and running torque across poses, temperatures and electrical states. | Task-specific force transparency and stable control; a low ratio alone is insufficient [cqdd-hand]. |
| Repeated and emergency pulses | Specify pulse shape, duration, speed before contact and lifetime count separately. | Supplier-approved routine spectrum; emergency rating only for its permitted events [harmonic-ratings]. |
| Bearing and structural endurance | Apply combined radial, axial and moment loads under representative oscillation and contamination. | Agree deflection, wear, backlash growth and life limits. ISO 281 bearing fatigue scope does not certify whole-joint endurance [iso-bearing]. |
| Commercial release | Review production drawings, inspection evidence, traceability and trial-batch results. | Written acceptance, warranty, NRE ownership, replacements and lead time; verify before series purchase. |
Sources & Primary Research Citations
Source checks below distinguish research prototypes, manufacturer rating terminology and public standard scopes. Page equations and examples are analytical derivations, not certified product data. No external source supplies the illustrative preset dimensions or universal qualification thresholds.
- Zhu, Tanaka, Rafeedi & Hong — Cycloidal Quasi-Direct Drive Actuator Designs with Learning-based Torque Estimation for Legged RoboticsarXiv:2410.16591v2, 20 March 2025; Table I and V-B; checked 12 November 2026
Research prototype context: a 10:1, 1.40 kg legged-robot actuator, with measured backlash 7.03 ± 1.3 arcmin and static backdrive torque 1.99 Nm. These results cannot establish miniature finger-joint performance or commercial availability.
View publication / catalog → - Harmonic Drive LLC — SHF/SHG component sets and housed units catalogTechnical Terms, printed page 12; checked 12 November 2026
Separates rated, repeated peak and momentary peak torque. Emergency events are excluded from normal cycles. These definitions help formulate supplier questions; this catalog does not rate a cycloidal candidate or validate an RMS factor.
View publication / catalog → - THK — Cross-Roller Ring: structure and featuresOfficial manufacturer guide; checked 12 November 2026
Describes support for radial, axial and moment loads. It does not establish an integrated bearing, moment capacity or available size for any hand reducer.
View publication / catalog → - ISO/TS 15066:2016 — Collaborative robotsOfficial public scope, 2016 edition; checked 12 November 2026
Applies to collaborative industrial robot systems and their environment. The public scope does not certify a hand, a reduction ratio, or a universal contact-force limit. Application risk assessment and full-system validation remain necessary.
View publication / catalog → - ISO 9283:1998 — Manipulating industrial robots: Performance criteria and related test methodsOfficial catalog entry; checked 12 November 2026
Robot-level performance test reference. The cited catalog entry does not prescribe component lost-motion thresholds; agree a gearbox test method and acceptance limits separately.
View publication / catalog → - ISO 281:2007 — Rolling bearings: Dynamic load ratings and rating lifeOfficial public scope, 2007 edition; checked 12 November 2026
Covers bearing dynamic ratings and rating life within its scope. It excludes wear, corrosion and electrical erosion; it is not a whole-gearbox grasp-cycle or oscillating-joint endurance certification.
View publication / catalog →
Humanoid Hand Joint Engineering FAQ
Loads and Calculation Boundaries
What does the humanoid hand joint sizing tool calculate?
It screens a direct, single-axis joint for perpendicular fingertip force, gravity, load acceleration, an assumed cycle RMS, motor speed and candidate scalar limits. It does not solve a full hand grasp or qualify a product.
When does gravity matter as much as pinch force?
It depends on pose and additional payload share. The default gives 1.275 Nm contact torque and 0.318 Nm gravity torque, so gravity is material. Do not assume that contact torque always dominates; set payload to zero if its loading is already represented by the contact-force input.
How do I enter the lever arm and angle?
Use the pivot-to-contact distance with contact force perpendicular to the lever. The model places finger CoM at half that distance and payload at the tip. Angle is measured from downward vertical. Other poses, multiple contacts or linked joints need CAD geometry and a Jacobian-based model.
Does an RMS factor of 0.45 cover sustained holding?
No. The continuous screen uses max(static holding torque, assumed cycle RMS). This conservative scalar check cannot calculate winding temperature or reducer life. Replace the assumed cycle with a measured trajectory and apply the exact supplier rating method.
Does the impact multiplier predict collision survival?
No. It scales scenario peak torque for sensitivity only. Collision response depends on inertia, stopping time, compliance and contact geometry. Routine impacts need approved repeated-pulse data; an emergency rating alone is insufficient.
Architecture and Integration
When is a compact cycloidal gearbox worth shortlisting?
Consider it when a supplier can demonstrate the needed torque, bore, envelope and operating life. Multi-contact load paths are a research motivation, not proof that a miniature design outperforms a particular planetary or strain-wave unit.
Does a lower ratio guarantee backdrivability or contact safety?
No. For the same motor, output-reflected rotor inertia scales as J_rotor × N²; changing 100:1 to 29:1 reduces that contribution by 91.59%. Friction, preload, gear inertia and control also matter. The tool reports N² only; it does not calculate actual inertia or contact safety.
What hollow bore should I specify?
Size it from the actual cable bundle, connector passage, bend radius and assembly clearances. The 3–6 mm examples are design inputs, not stock dimensions. No universal 65% bore-to-OD rule is assumed; request a supplier section drawing.
Is a cross-roller bearing mandatory?
No. A suitable integrated or external bearing system must carry the actual radial, axial and overturning loads with acceptable deflection. THK describes the multi-directional load capability of cross-roller rings, but hand-scale availability and ratings remain unverified.
Can I use this calculator for a remote tendon actuator?
It can estimate a direct-joint load only. A remote tendon system also needs tendon moment arms, pulley radius, routing friction, preload, compliance and the transmission Jacobian to convert joint torque into reducer torque and speed. Request a manual review with routing drawings.
Sourcing and Qualification
Does an entered-limit match qualify a gearbox?
No. Blank candidate data stays pending, and a match means only that entered scalar values cover modeled demands. Verify datasheet provenance, motor torque-speed capability, thermal derating, bearing life and prototype performance.
What must I send for an engineering RFQ?
Send force vectors and contact poses, CAD mass properties, trajectory and hold times, motor curves and bus voltage, package and bore drawings, bearing loads, collision pulse requirements, ambient conditions and quantities. Copy the tool summary as a starting point.
How do repeatable peak and emergency ratings differ?
Normal acceleration and deceleration use repeatable peak ratings. Emergency momentary ratings have restricted duration and occurrence counts. Get supplier approval for the actual routine impact spectrum rather than substituting emergency capacity.
What backlash or temperature limits should I use?
Derive lost motion from the allowed fingertip error and pose geometry, and temperature limits from motor insulation, lubricant, sensors and touch surfaces. This page supplies no universal 1–3 arcmin or 70°C acceptance threshold. Agree test conditions and limits before ordering.
How do I manage sourcing cost and lead-time risk?
Confirm whether the envelope needs a custom component set, then request NRE, tooling, minimum order, prototype and production lead times, yield assumptions and replacement terms. Availability, prices and delivery dates are not verified here; compare a larger palm package or alternative transmission.
Engineering RFQ Checklist & Next Steps
To request an application review, candidate feasibility check, or prototype quotation, provide your joint parameters using this checklist:
| Requirement Category | Parameters to Specify | Design Impact |
|---|---|---|
| Grasp & Motion Profile | Normal pinch force (N), finger reach (mm), peak velocity (deg/s), acceleration (deg/s²). | Defines a load screen; add hold times, force directions and trajectory before ratio and thermal selection. |
| Spatial & Bore Envelope | Max outer diameter (mm), axial length (mm), min hollow bore diameter (mm). | Governs disc eccentricity, pin ring diameter, and sensor cable passage. |
| Lateral Load & Moment | Overturning moment (Nm), off-axis wrench, radial/axial external forces. | Sizes integrated miniature crossed-roller bearing and flange stiffness. |
| Electrical & Motor Data | DC bus voltage, motor model/KV, max phase current, encoder type. | Ensures torque-speed compatibility and prevents input speed overdrive. |
| Environmental & Volume | Operating temperature range, IP sealing rating, prototype vs annual production quantity. | Selects lubricant formulation, seal design, and manufacturing tooling tier. |
Inquiry Email
Include target torque/speed, quantity, and delivery location.